Hugo Pousseur
Robotics engineer, from low-level integration to autonomous navigation. Here you'll find my projects, scientific articles and technical notes, mainly focused on autonomous vehicles, robotics and real-time systems. Feel free to explore, and don't hesitate to reach out!

Explore by topic
All topics →Selected projects
All projects →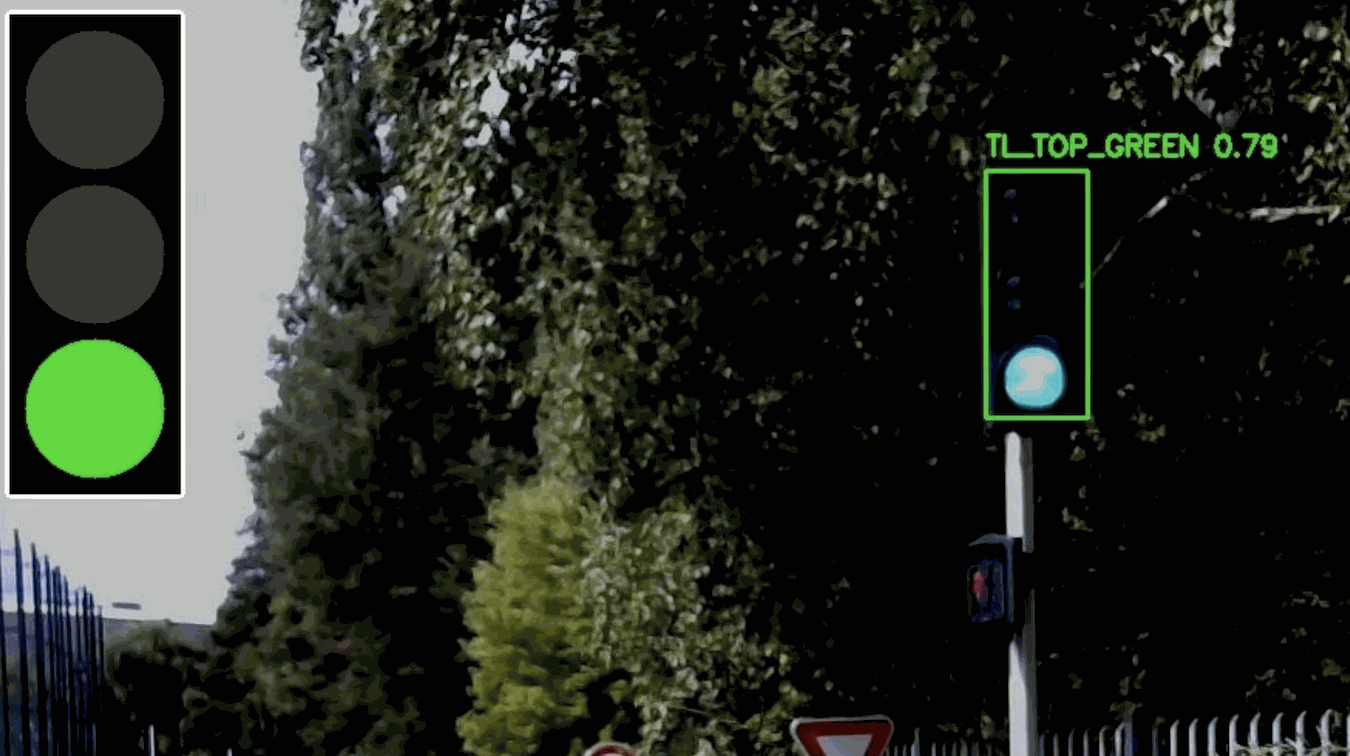 15 May 2025
Traffic Light Detection & Control
Detection of traffic lights, and adaptation of vehicle control depending on the light state.
 20 Dec 2024
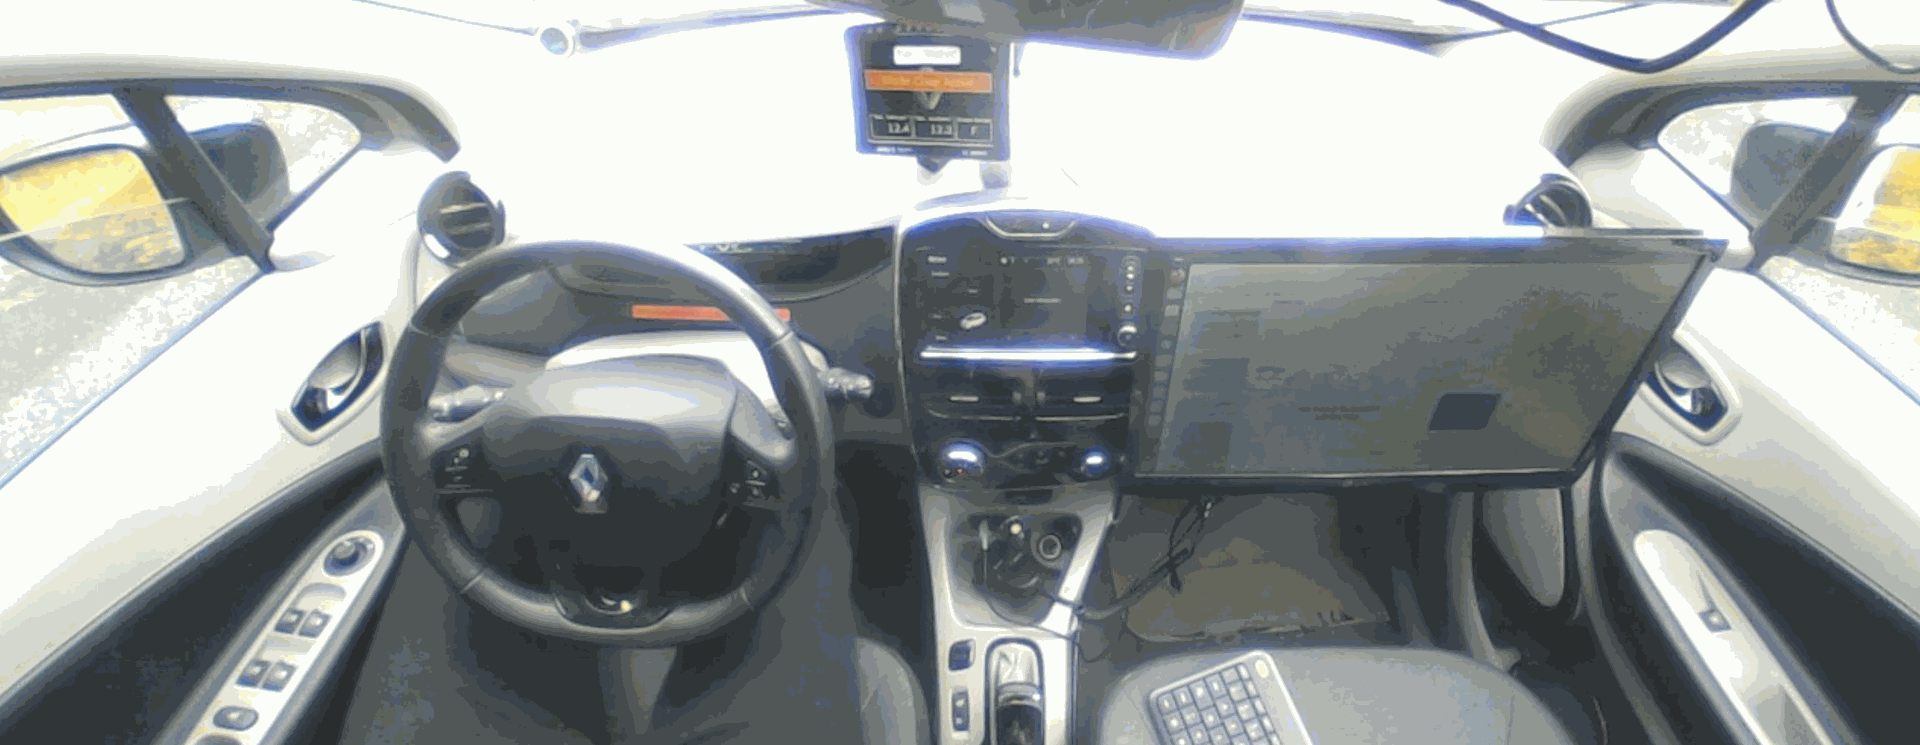
Autonomous Vehicle: Control
Lateral and longitudinal control applied to a real autonomous vehicle, integrated with a navigation layer.
 10 Dec 2024
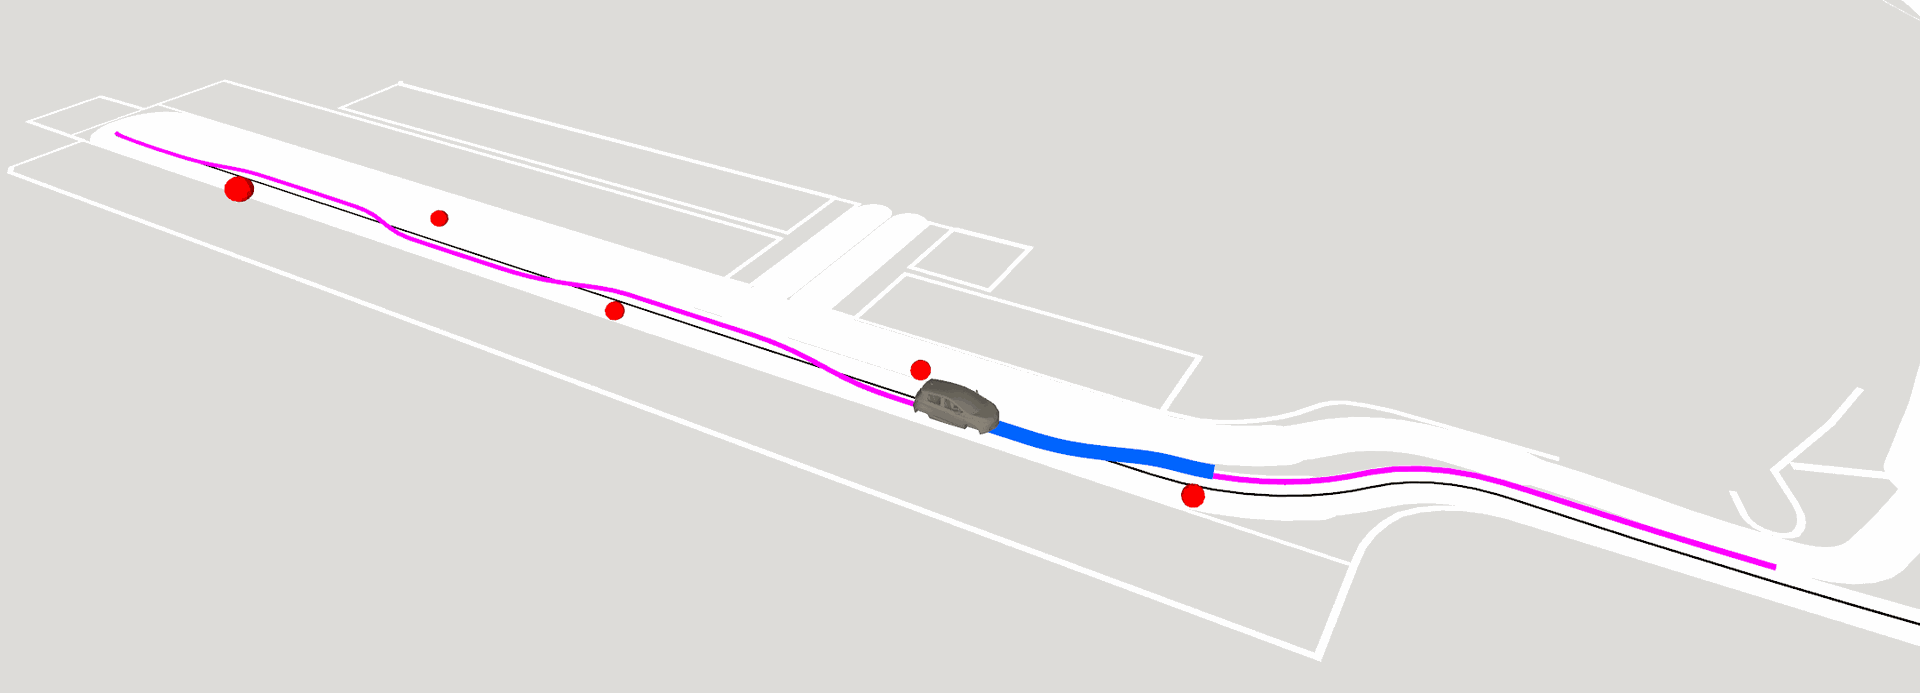
Autonomous Vehicle: Planning
Local planning applied to real autonomous vehicles, combining global route planning, local path adjustment, and dynamic control …
Latest posts
All posts →URDF: The One File Every ROS 2 Robot Tool Reads
What a URDF stores, what it leaves out, and how robot_state_publisher, RViz, MoveIt, Gazebo and ros2_control all read the same description: from a joint angle to a TF frame.
Cyclone DDS vs Fast DDS: Two Implementations of the Same Standard, and Which One to Use with ROS 2
Why both are called DDS, what the standard and RTPS fix and what they leave to each vendor, where Cyclone DDS and Fast DDS come from, why ROS 2 switched its default between them, and how to choose one for a project.
A Month of Liguria's Trains: What 22,641 Trips and 231,504 Arrivals Say About the Network
Step two of my train tracking project: before building the model, a statistical look at the trains recorded around Genoa. What runs, when, and how late, with the equations behind every figure.
GitHub activity
@PouceHeure →Thesis: Shared navigation in a cybernetic multi-agent autonomous system
Latest videos
Teleoperation Demo. (Train Demo)
Video demo of the LiDAR Detection pipeline
Demo video: autonomous vehicle adapting control based on traffic light detection.